LightForce OEM
Introduction
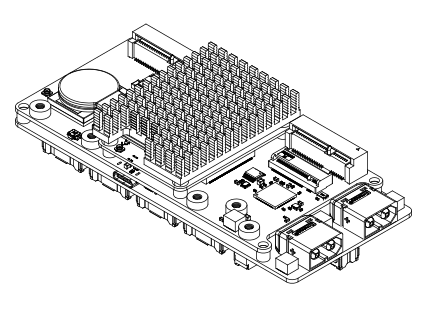
LightForce OEM is designed to provide the foundational control and processing features of the LightForce platform. This model consolidates essential system components into a compact footprint for direct integration into third-party hardware. It provides localized processing for critical system tasks, standardized communication interfaces for peripheral connectivity, and direct access to the platform’s primary logic controllers. This model is intended for applications requiring maximum architectural flexibility.
System Features
Feature Table
| Feature | Standard Configuration |
|---|---|
| Mission Processor | 4x Cortex-A76 at 2.5GHz |
| I/O Processor | 2x Cortex-M33 at 150MHz |
| Embedded GPU | VideoCore VII at 800 MHz |
| Storage | 16GB eMMC 1TB internal M.2 NVMe SSD |
| Internal Sensors | IMU Dual Antenna RTK GNSS |
| Communications | Wifi Bluetooth Internal bay (mPCIe) supports all ISM bands LTE Sat Fibre optics |
| Buses | 1x 4-lane MIPI CSI 2x 1Gbps Ethernet 1x USB2 OTG at 480Mbps 16x PWM 1x I2C 1x CAN FD at 8Mbps 16x UART (SW selectable) 16x RS422/485 (SW selectable) 16x RS232 (SW selectable) 8x GPIO 8x ADC |
The performance and functionality of LightForce is enhanced through optional hardware modules and software modules. See the Modularity section for more information.
Modularity
The LightForce architecture is built on a foundation of versatile, interoperable modules designed to provide high-performance autonomy across diverse operational environments. By decoupling core flight intelligence from hardware-specific sensing and control, the system offers a scalable "plug-and-play" framework. Whether deployed on a single vehicle or integrated into a complex System of Systems (SoS), these capabilities can be tailored to meet specific mission requirements, ensuring maximum reliability and tactical flexibility.
Intelligence
- Detect & Avoid
- Smart Health Monitoring
- Dynamic Path Planning
- Swarming
Navigation
- Dead Reckoning
- Vision-based guidance
- GNSS Spoof/Jam Detection
Advanced Control
- Adaptive
- Non-linear
- Tethered
External Sensors
- Lidar
- Airdata (Multi-hole Pitot)
- Fibre Optic Gyroscope IMU
- Visual / Thermal Camera
Safety
- Flight Termination (FTS)
- ADS-B / Remote ID
- Triple Redundant Voting
- Geofencing
Communication
- SATCOM
- Fibre Optics
- MAVLink
Actuators & Motors
- Servo
- Stepper
- BLDC
- +
Ground Support
- Ground Control Station
- SIL / HIL
- Mission Planning
Platforms
- UAV / USV / UGV
- Hybrid Robotic Systems
- Coordinated Swarms
- Systems of Systems (SoS)
Technical Specifications
Mechanical Specifications
The LightForce OEM is engineered with a ruggedized, weight-optimized mechanical architecture suitable for integration into a wide range of unmanned and autonomous platforms. Its compact form factor, reinforced mounting interfaces, and vibration-tolerant construction enable reliable operation in demanding mobile environments, while maintaining compatibility with typical structural configurations.
Dimensions
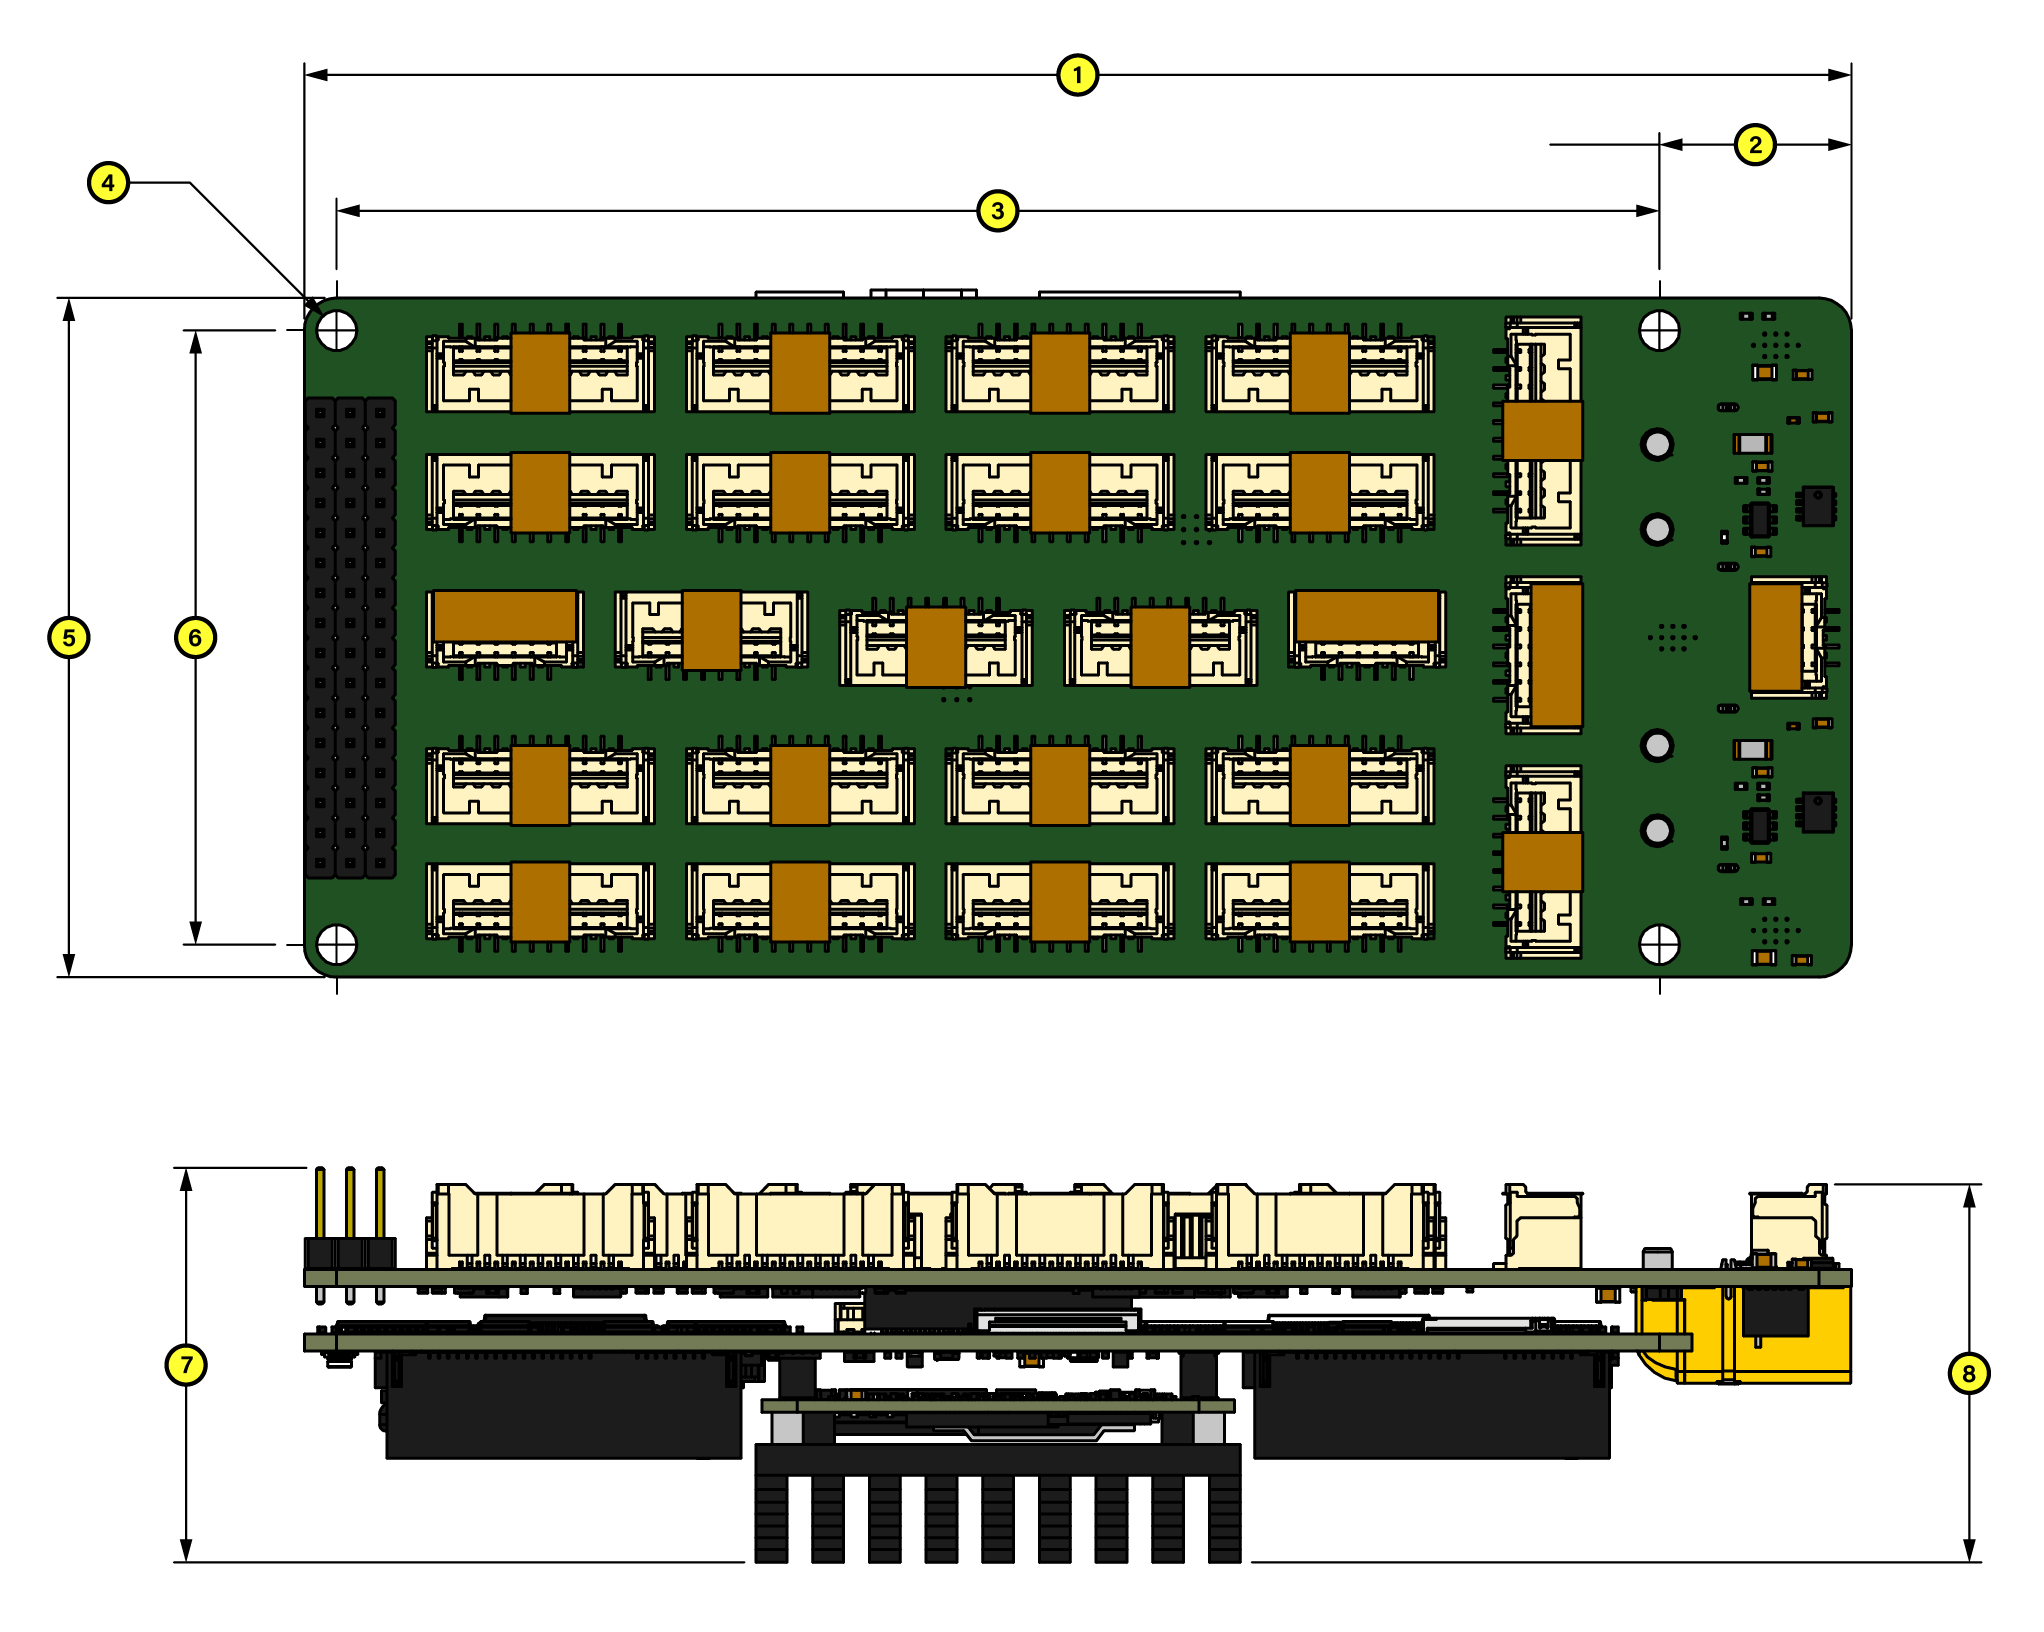
The following diagram provides an overview of the hardware's physical dimensions to assist with system integration. Key measurements are indicated to ensure proper alignment with external mounting points and connectors.
Dimensions
| Label No. | Dimension |
|---|---|
| 1 | 131.00 mm |
| 2 | 16.25 mm |
| 3 | 112.00 mm |
| 4 | 3.40 mm |
| 5 | 57.50 mm |
| 6 | 52.00 mm |
| 7 | 33.44 mm |
| 8 | 32.00 mm |
Orientation
LightForce offers full mounting flexibility regardless of spatial orientation. Software-based alignment to the airframe is managed through the configuration settings, supporting both rotation matrix inputs and direct axis-mapping.
Orientation
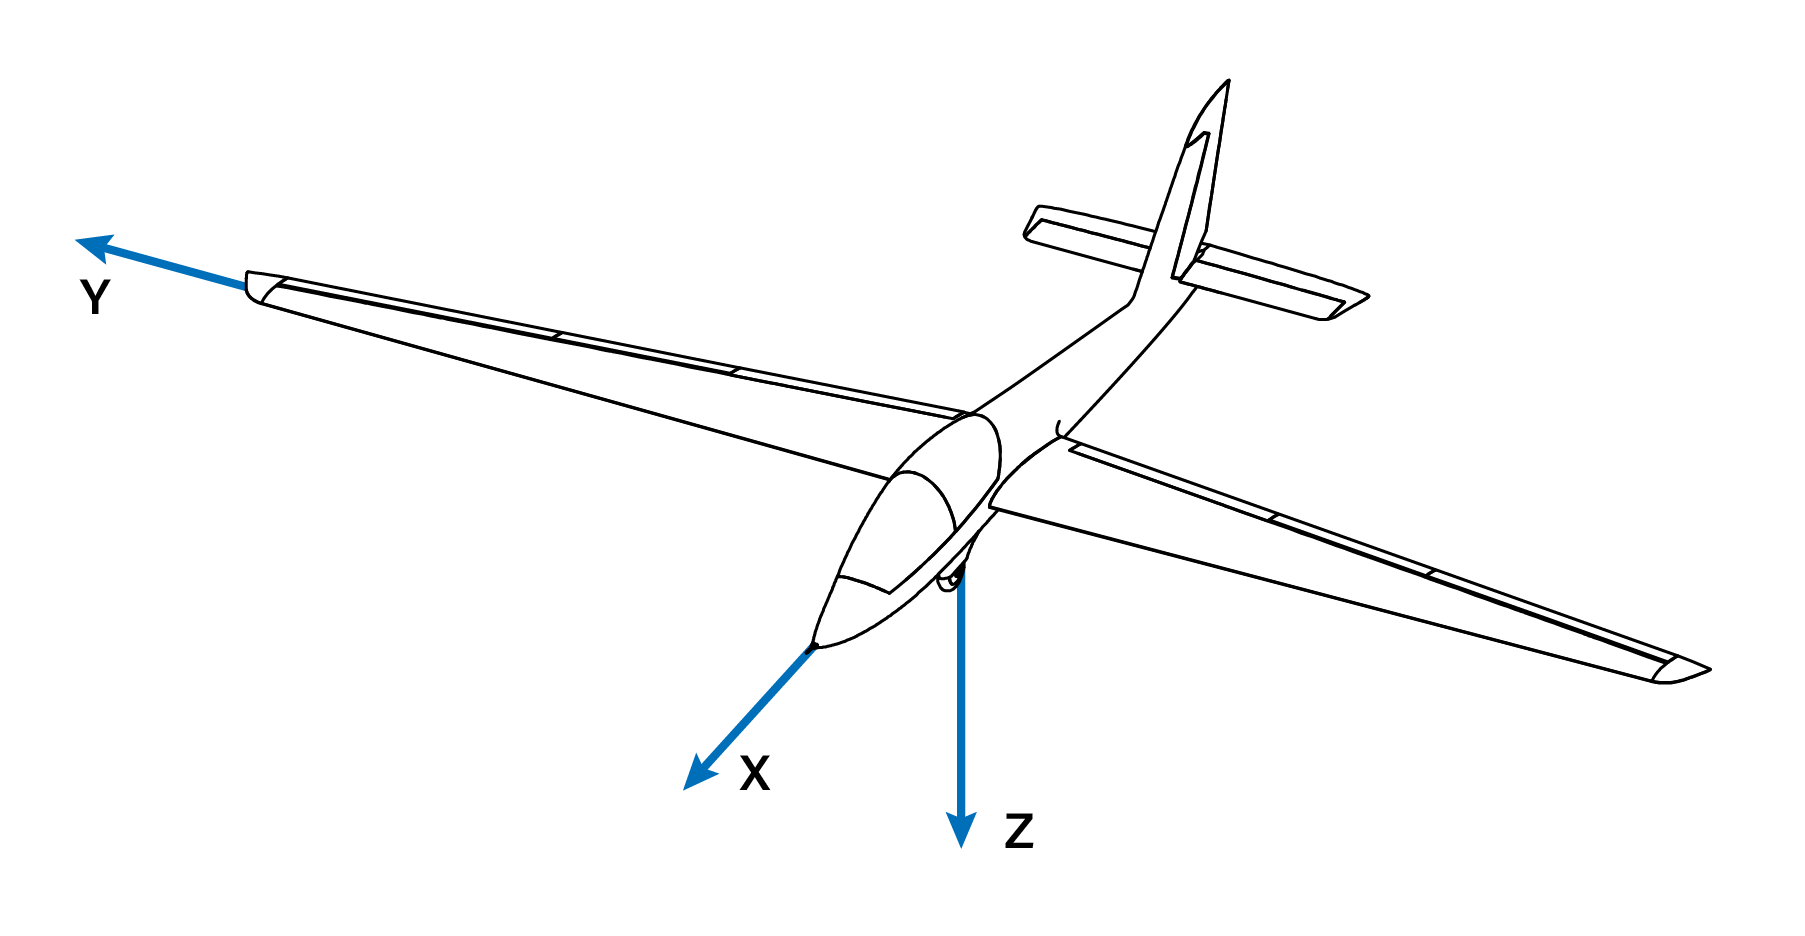
Axes are indicated on the LightForce enclosure. For reference, the coordinate system is shown in the image at right.
Position
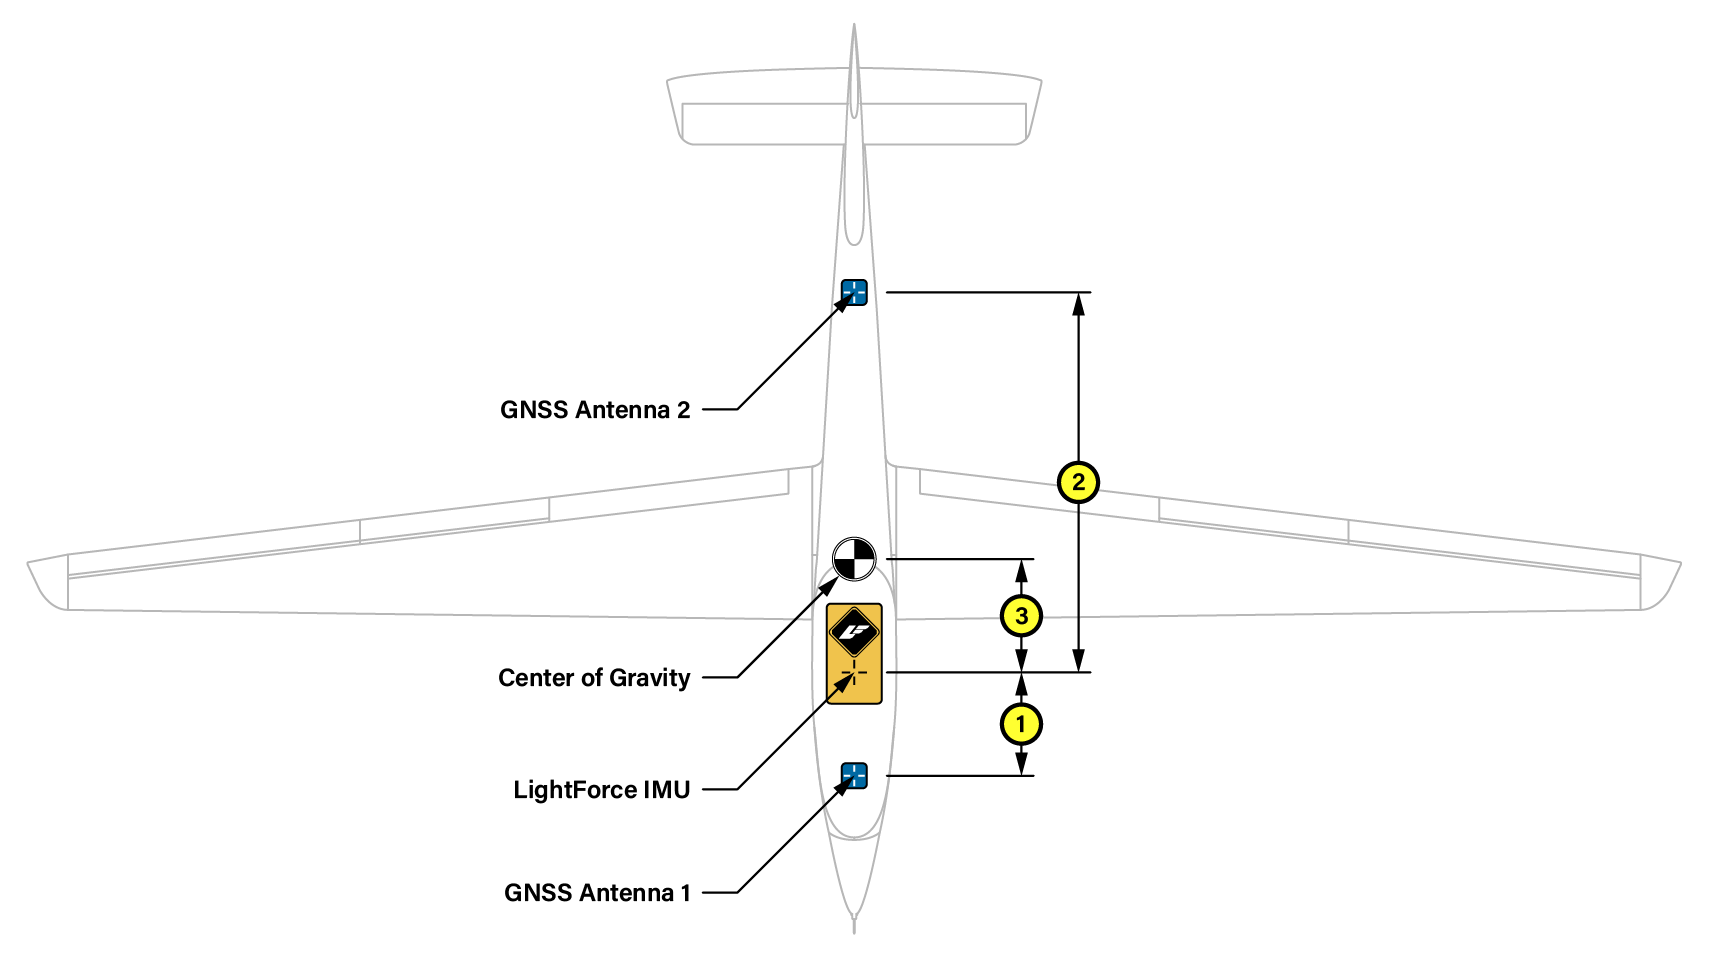
To ensure accuracy when using traditional navigation, the physical spatial relationship between the LightForce IMU and the vehicle's key reference points must be established. This is achieved by inputting the position vectors within the configuration interface.
Spatial Offset Configuration Provide two distinct sets of vector inputs:
- Dual-Antenna Baseline: Define the relative position of the two GNSS antennas with respect to the LightForce IMU center. These vectors allow the system to calculate precise heading and multi-antenna positioning.
- Center of Gravity (CG) Alignment: Define the vector from the LightForce IMU to the vehicle’s Center of Gravity, including the relative orientation expressed with Euler angles (i.e. roll, pitch, and yaw). Accurately mapping this offset is critical for the IMU to correctly compensate for centrifugal forces and rotations during high-dynamic maneuvers.
All coordinates should be entered in accordance with the primary coordinate system (typically Forward-Right-Down or X-Y-Z), ensuring that the translated data reflects the true physical displacement of the hardware relative to the airframe.
Position
| Label No. | Description | Input |
|---|---|---|
| 1 | ANT1_OFFSET | X, Y, Z |
| 2 | ANT2_OFFSET | X, Y, Z |
| 3 | IMU_OFFSET | X, Y, Z, ψ, θ, φ |
Mechanical Installation
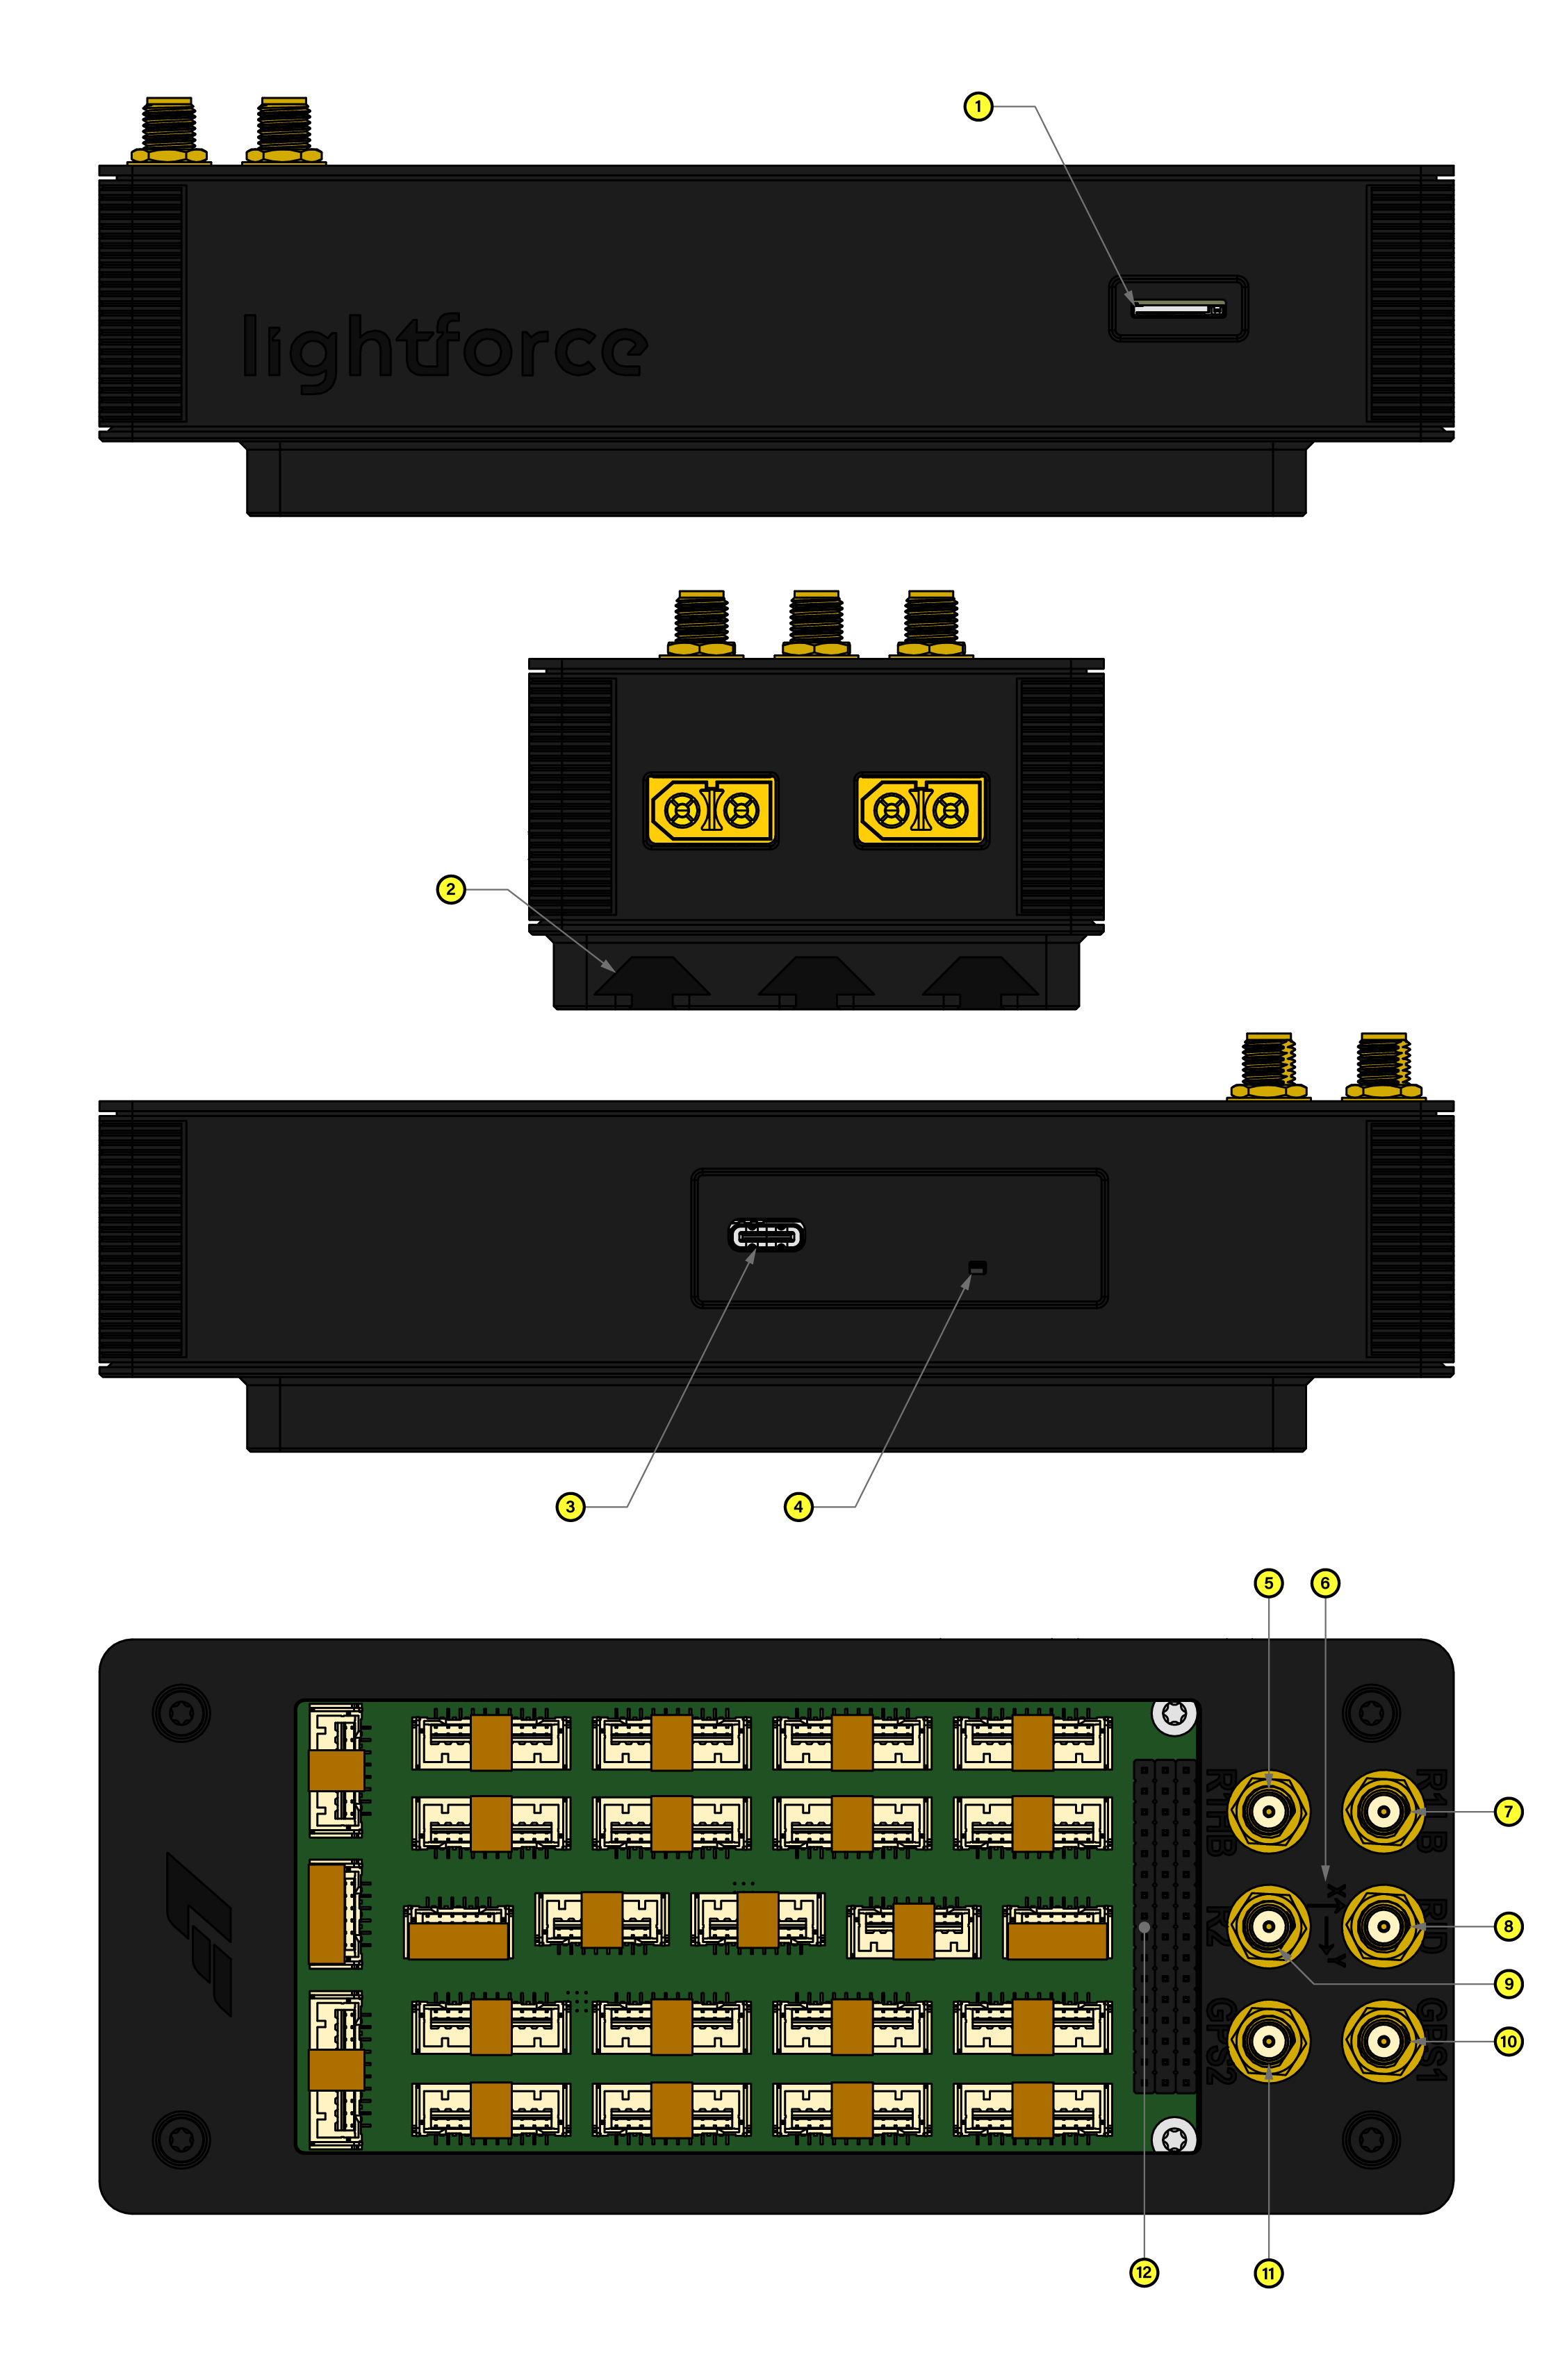
Successful deployment of the LightForce system depends on secure mounting within your vehicle or system. By default, LightForce OEM is delivered with a basic, non-ruggedized enclosure for everyday handling protection which is appropriate for benchtop testing, drive tests, and operations in optimal environmental conditions. For more information about the interfaces, consult the Interfaces section.
Basic Enclosure
| Label No. | Interface | Description |
|---|---|---|
| 1 | SIM | Nano SIM card for LTE modem |
| 2 | MOUNT | Bottom plate can be replaced to match any mounting style; default is standard T-slot |
| 3 | USB | Host connection; USB-C |
| 4 | BOOT | Used to enter Bootloader Mode |
| 5 | R1LB | Low-band radio connector; ELRS |
| 6 | AXES | Configured orientation axes of LightForce |
| 7 | R1HB | High-band radio connector, ELRS |
| 8 | RID | Remote ID connector |
| 9 | R2 | Alternative radio connector; LTE/LOS/Other |
| 10 | GPS1 | Primary GNSS antenna connector |
| 11 | GPS2 | Secondary GNSS antenna connector |
| 12 | IOB | I/O Board interface connectors |
Electrical Specifications
The LightForce OEM is designed to operate within a standard industrial temperature range and provides a versatile I/O architecture compatible with modern UAV peripherals.
| Parameter | Min | Typ | Max | Unit |
|---|---|---|---|---|
| Operational Temperature | -40 | — | +85 | °C |
| Logic Level (High) | 2.3 | 3.3 | 3.6 | V |
| Logic Level (Low) | -0.3 | 0 | 0.8 | V |
| PWM Output Frequency | 50 | 400 | 2000 | Hz |
| ADC Resolution | — | 12 | — | Bits |
| Input Voltage (VBUS) | 5.0 | — | 32.0 | V |
| Total Power Consumption | — | 4.5 | — | W |
| I/O Current Drive (Per Pin) | — | — | 15 | mA |
| ESD Protection (Human Body Model) | — | TBD | — | kV |
| Shock Tolerance | — | — | TBD | g |
Power
The LightForce OEM architecture is engineered for high-availability missions, utilizing a redundant power-entry system and isolated regulation domains to ensure that peripheral faults do not compromise flight-critical logic.
Primary Power Input (BUSA & BUSB)
The system is powered via two independent primary input buses, BUSA and BUSB, utilizing XT60 connectors.
- Voltage Range: 5V-32V (Supports 2s to 7s LiPo/Li-ion).
- Redundancy & Failover: Both inputs are fed into an integrated Power Mux. The system employs a "highest-voltage-priority" logic meaning that the source with the higher potential provides the primary load.
- UPS Configuration: This architecture allows for Uninterrupted Power Supply (UPS) setups. For example, a ground station can be powered by a mains DC supply (set to a higher voltage) with a battery backup (at a lower voltage) that instantly takes over if mains power is lost.
- Power Switching: The unit features a dedicated Switch Connector with low-current "Enable" pins.
- Default State: The system is Fail-ON. If no switches are connected, the unit powers up as soon as a battery is connected.
- Manual Control: Two separate low-current switches can be wired to this header to independently toggle the power domains.
Voltage Rails & Regulation
The Power Mux feeds the common internal rail VBUS with a total current capacity of 25A. From this, the system derives three secondary regulated domains and one high-power pass-through.
| Rail | Voltage | Max Current | Source | Description |
|---|---|---|---|---|
| 5V_LOGIC | 5.0V | Internal | Regulated | Core CPU and internal sensors and radios. |
| 5V_SERVO | 5.0V | 4A | Regulated | External 5V peripherals/small servos. |
| 3.3V_EXT | 3.3V | 4A | Regulated | External low-voltage sensors. |
| Output Channels | VBUS | 25A (Total) | Direct | Pass-through of BUSA/BUSB voltage. |
5V_LOGIC and 5V_SERVO are fully independent. High-current transients or brown-outs on the servo rail will not affect the stability of the core flight logic.
Output Channels
The LightForce OEM provides 16 high-power output channels. These channels are designed for high-performance actuators and external peripherals.
- Output Voltage: These channels output Direct Input Voltage (VBUS).
- Individual Protection: Each channel is equipped with a dedicated monitoring and protection IC, hardware-limited to 5A.
- Fault Isolation & Recovery: If a short circuit or over-current event occurs, the system automatically cuts power to that specific channel without affecting the rest of the unit or other output channels. Once the fault is cleared, power is automatically restored.
- Common Ground: The system utilizes a common ground architecture across all 16 channels and power domains to ensure signal integrity and simplified wiring.
Since the output channels provide direct input voltage, users must ensure that all attached actuators/servos and peripherals are rated for the full voltage range of your input (i.e. battery). Do not connect standard 5V/6V servos to these channels unless your input voltage is regulated to those levels.
Telemetry & Diagnostics
An onboard high-precision ADC provides real-time analytics for the entire power ecosystem:
- Input Health: Voltage and current tracking for BUSA and BUSB in order to determine the remaining charge.
- Per-Channel Monitoring: Live current draw for all 16 output channels in order to determine fault conditions. Real-time data allows the operator to detect "stalled" or degrading servos via current-draw spikes before they lead to mechanical failure.
Thermal Management
Note: Thermal performance specifications are currently under evaluation. While the system is rated for an aggregate of 25A, high-load operations generate heat. Ensure the unit is mounted in an area with adequate airflow.
Interfaces
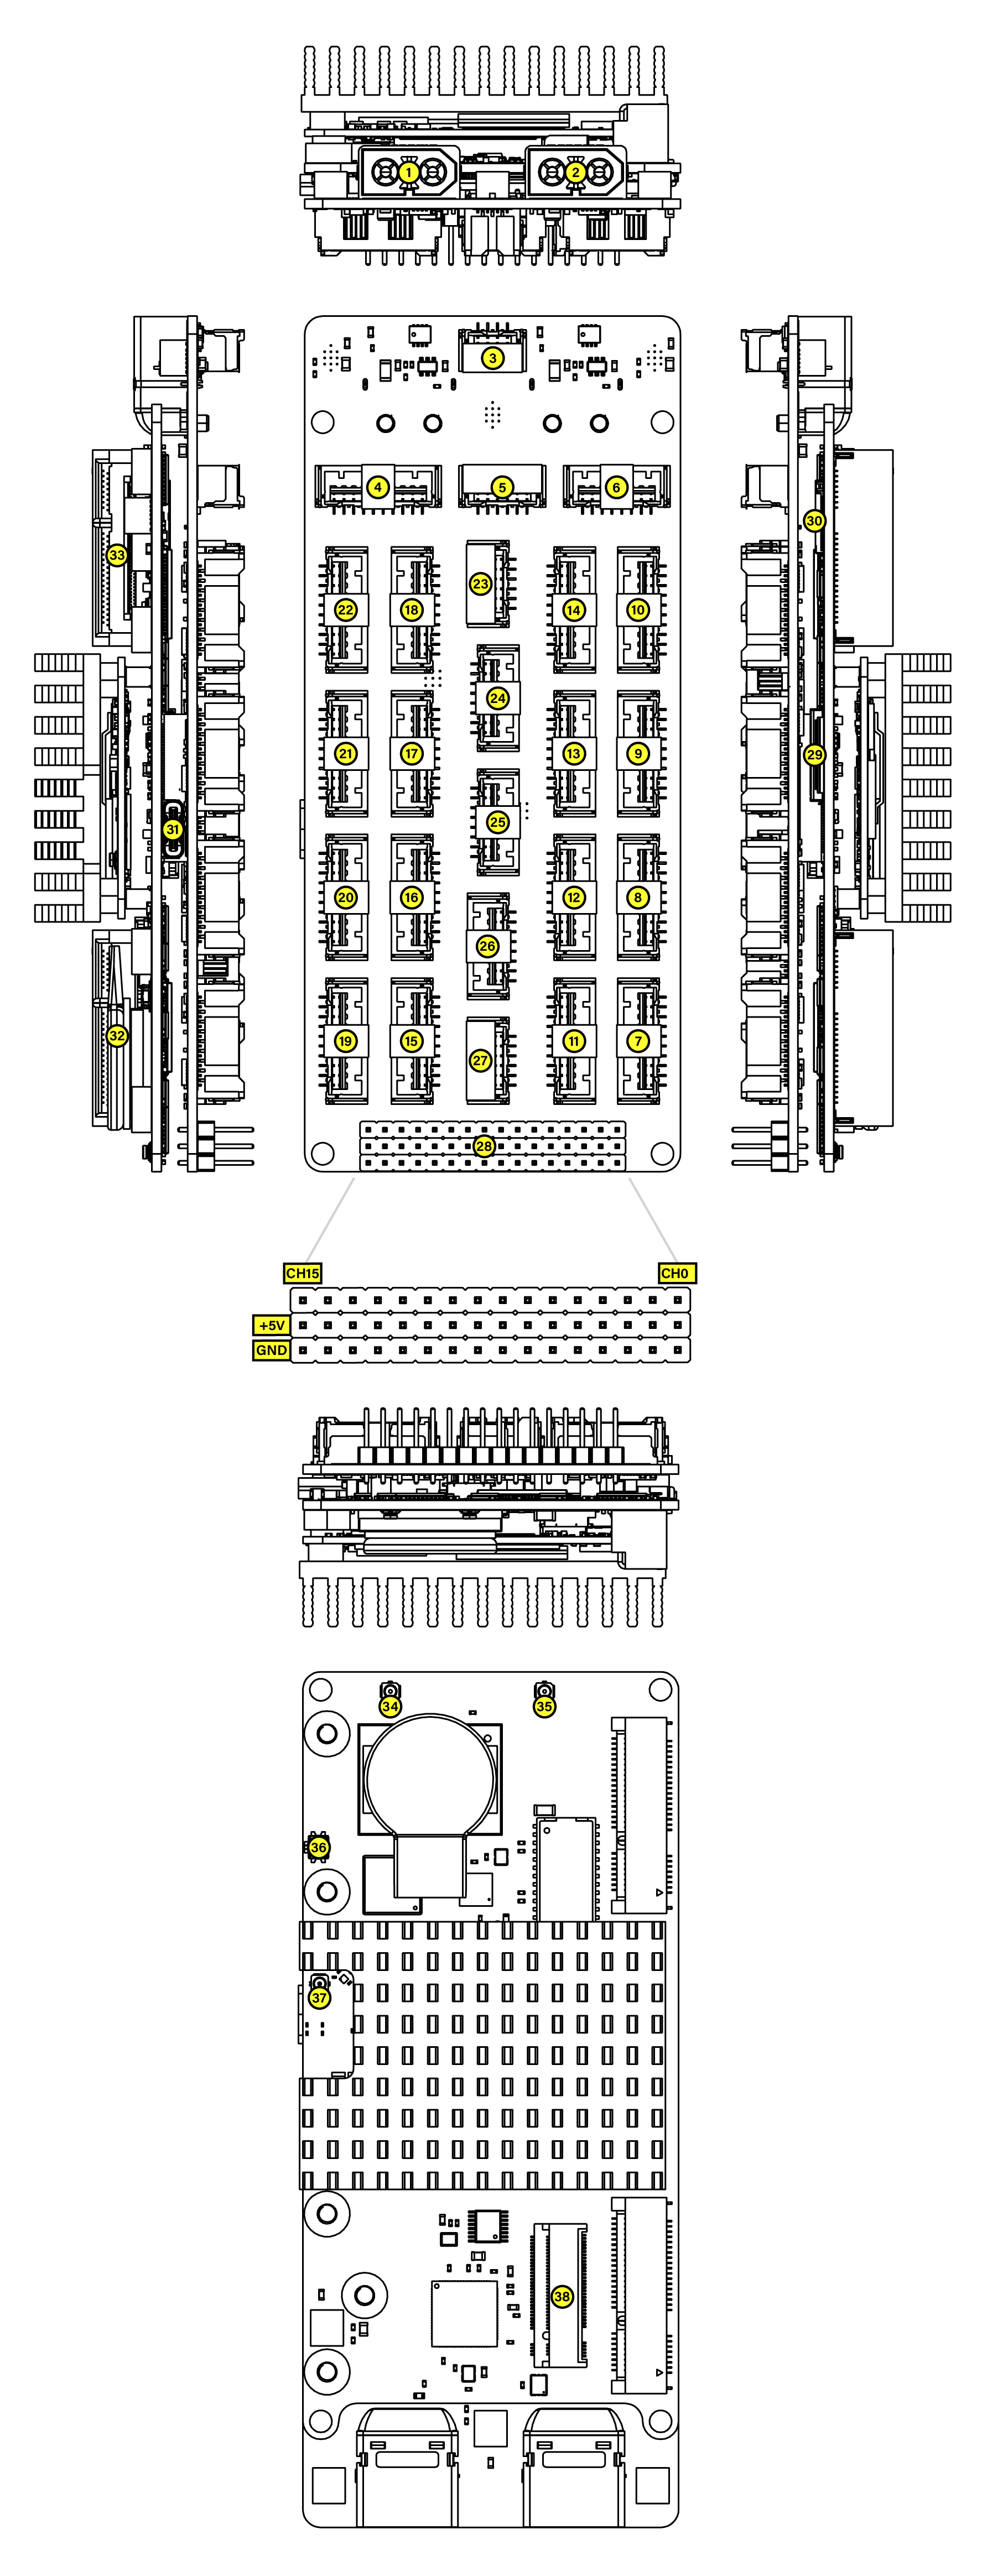
The LightForce OEM PCBA features a highly integrated interface architecture designed to balance high-speed data throughput with versatile peripheral control. The layout is organized into functional zones, supporting a wide array of industrial protocols including Dual Ethernet (ETH0/1), CAN bus, and I2C, alongside dedicated headers for Servo and Camera integration.
Furthermore, the board provides 16 primary signal channels (CH0–CH15) and multiple MCU-direct I/O ports, offering extensive flexibility for sensor arrays and custom logic interfacing. This streamlined distribution of interfaces ensures minimal signal interference while facilitating clean cable management within complex system integrations.
Interfaces
| Label No. | Signal | Type | Description |
|---|---|---|---|
| 1 | PWR_B | XT60-M | Secondary power input |
| 2 | PWR_A | XT60-M | Primary power input |
| 3 | PWR_SWITCH | Molex CLIK-Mate (1.50mm) 4 Position | Switch connector |
| 4 | MCU_I0 | Molex CLIK-Mate (1.50mm) 10 Position | MCU IO connector |
| 5 | I2C | Molex CLIK-Mate (1.50mm) 6 Position | I2C Connector |
| 6 | MCU_ADC2 | Molex CLIK-Mate (1.50mm) 8 Position | MCU ADC 2 connector |
| 7 | CH0 | Molex CLIK-Mate (1.50mm) 10 Position | Serial channel 0 connector |
| 8 | CH1 | Molex CLIK-Mate (1.50mm) 10 Position | Serial channel 1 connector |
| 9 | CH2 | Molex CLIK-Mate (1.50mm) 10 Position | Serial channel 2 connector |
| 10 | CH3 | Molex CLIK-Mate (1.50mm) 10 Position | Serial channel 3 connector |
| 11 | CH4 | Molex CLIK-Mate (1.50mm) 10 Position | Serial channel 4 connector |
| 12 | CH5 | Molex CLIK-Mate (1.50mm) 10 Position | Serial channel 5 connector |
| 13 | CH6 | Molex CLIK-Mate (1.50mm) 10 Position | Serial channel 6 connector |
| 14 | CH7 | Molex CLIK-Mate (1.50mm) 10 Position | Serial channel 7 connector |
| 15 | CH8 | Molex CLIK-Mate (1.50mm) 10 Position | Serial channel 8 connector |
| 16 | CH9 | Molex CLIK-Mate (1.50mm) 10 Position | Serial channel 9 connector |
| 17 | CH10 | Molex CLIK-Mate (1.50mm) 10 Position | Serial channel 10 connector |
| 18 | CH11 | Molex CLIK-Mate (1.50mm) 10 Position | Serial channel 11 connector |
| 19 | CH12 | Molex CLIK-Mate (1.50mm) 10 Position | Serial channel 12 connector |
| 20 | CH13 | Molex CLIK-Mate (1.50mm) 10 Position | Serial channel 13 connector |
| 21 | CH14 | Molex CLIK-Mate (1.50mm) 10 Position | Serial channel 14 connector |
| 22 | CH15 | Molex CLIK-Mate (1.50mm) 10 Position | Serial channel 15 connector |
| 23 | CAN | Molex CLIK-Mate (1.50mm) 6 Position | CAN connector |
| 24 | MCU_ADC1 | Molex CLIK-Mate (1.50mm) 8 Position | MCU ADC 1 connector |
| 25 | ETH1 | Molex CLIK-Mate (1.50mm) 8 Position | Ethernet connector |
| 26 | ETH0 | Molex CLIK-Mate (1.50mm) 8 Position | Ethernet connector |
| 27 | MCU_DBG | Molex CLIK-Mate (1.50mm) 6 Position | MCU debug connector |
| 28 | SERVO | 2.54" Pin Header | 16 channel standard PWM |
| 29 | CAMERA | Hirose FH12-22S-0.5SH | RPi camera connector |
| 30 | SIM | Nano SIM Card | Nano SIM Card for LTE modem |
| 31 | USB | USB-C | Host connection |
| 32 | RADIO2 | mPCIe | Connected to USB hub and /dev/ttyAMA4 |
| 33 | RADIO1 | mPCIe | Connected to USB hub and /dev/ttyAMA2 |
| 34 | GNSS2 | UF.L | Secondary antenna (for heading) |
| 35 | GNSS1 | UF.L | Primary antenna (for position) |
| 36 | BOOT | Push Switch | Used to enter Bootloader Mode |
| 37 | REMOTE_ID | UF.L | 2.4GHz antenna |
| 38 | NVME | M.2 (M Key) | NVMe SSD storage for data logging |
Pinout
The LightForce OEM unit uses industry-standard Molex Click-Mate 1.5mm pitch connectors for most external interfaces. These connectors provide reliable, tool-free mating and unmating capabilities, ensuring secure connections during operation while maintaining ease of maintenance and field reconfiguration.
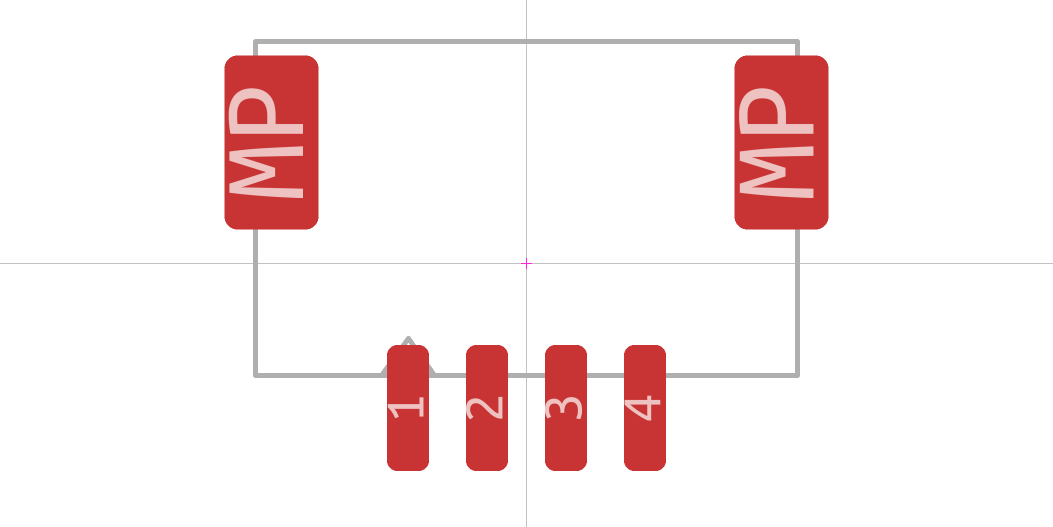
Switch Connector
| Pin | Signal | Type | Description |
|---|---|---|---|
| 1 | GND | Ground | Ground (-) |
| 2 | BUSA_EN | Input (pull-up) | Bus A enable input |
| 3 | GND | Ground | Ground (-) |
| 4 | BUSB_EN | Input (pull-up) | Bus B enable input |
Serial Channel Connector
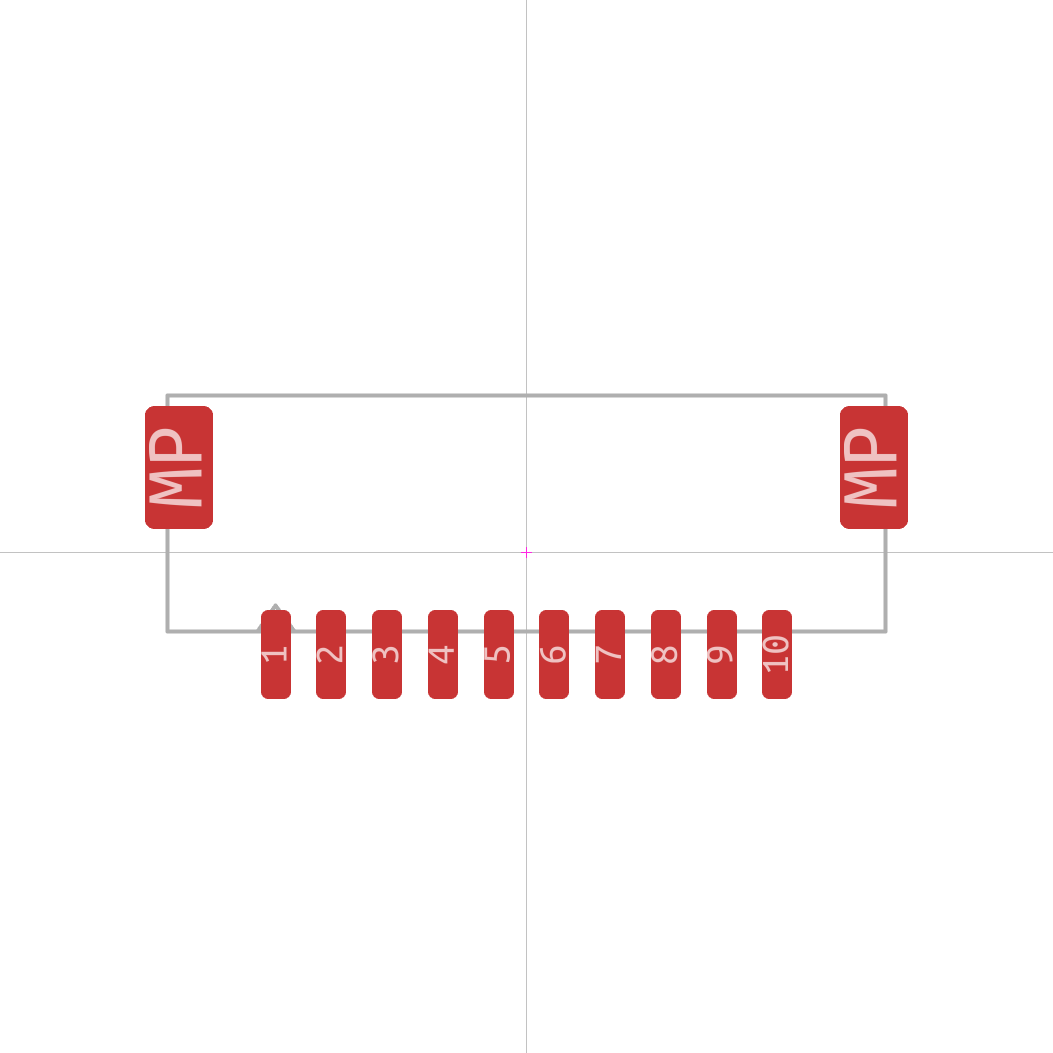
| Pin | Signal | Type | Description |
|---|---|---|---|
| 1 | GND | Ground | Ground (-) |
| 2 | 5V_SERVO | Power | 5V supply dedicated for servos (4A total) |
| 3 | PWM | Output (3.3V) | PWM output signal |
| 4 | TTL_RX | Input (3.3V) | UART RX signal |
| 5 | TTL_TX | Output (3.3V) | UART TX signal |
| 6 | RS232_RX/RS422_RX_A | Input | RS232 RX or RS422_RX A signal (software selectable) |
| 7 | RS422_RX_B | Input | RS422_RX B signal (software selectable) |
| 8 | RS232_TX/RS422_TX_Z/RS485_B | I/O | RS232 TX or RS422_TX Z or RS485 B signal (software selectable) |
| 9 | RS422_TX_Y/RS485_A | I/O | RS422_TX Y or RS485 A signal (software selectable) |
| 10 | VSUPPLY | Power (5V-32V) | Dedicated monitored and protected supply channel (5A) |
Ethernet Connector
| Pin | Signal | Type | Description |
|---|---|---|---|
| 1 | TR0+ | I/O | |
| 2 | TR0- | I/O | |
| 3 | TR1+ | I/O | |
| 4 | TR1- | I/O | |
| 5 | TR2+ | I/O | |
| 6 | TR2- | I/O | |
| 7 | TR3+ | I/O | |
| 8 | TR3- | I/O |
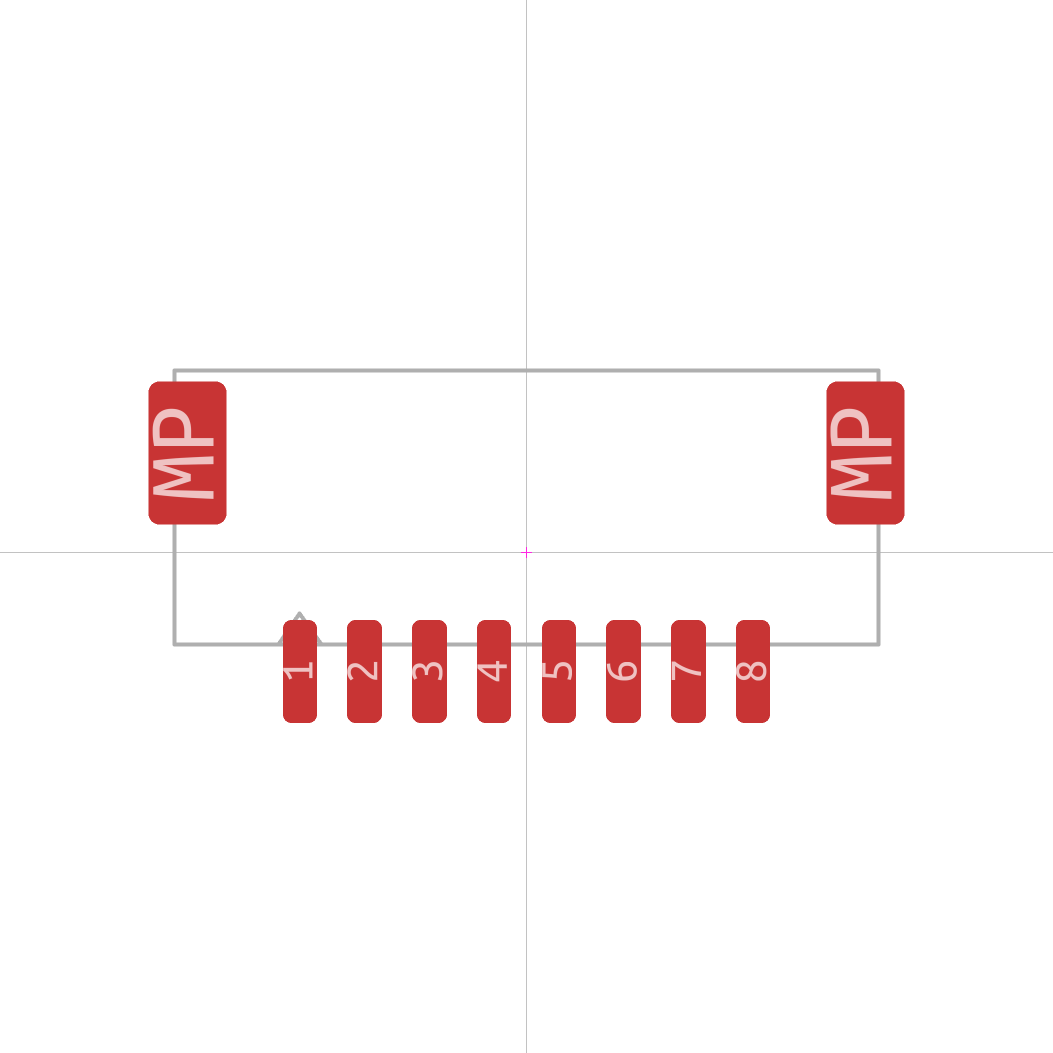
CAN Connector
| Pin | Signal | Type | Description |
|---|---|---|---|
| 1 | GND | Ground | Ground (-) |
| 2 | VBUS | Power (5V-32V) | Redundant power bus (5A total) |
| 3 | 5V_LOGIC | Power (5V) | 5V logic supply (1A total) |
| 4 | 3V3_LOGIC | Power (3.3V) | 3.3V logic supply (2A total) |
| 5 | CAN_H | I/O (5V) | CAN high signal |
| 6 | CAN_L | I/O (5V) | CAN low signal |
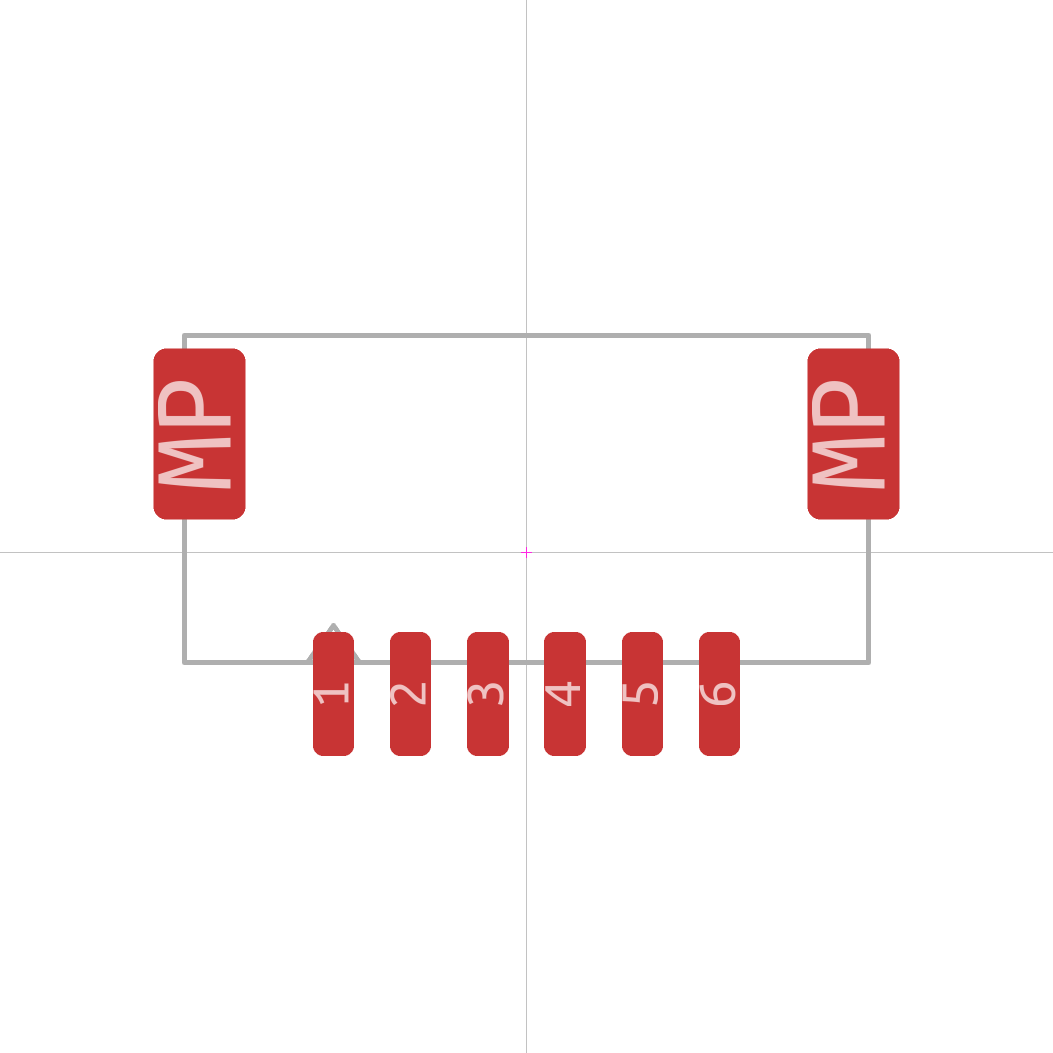
I2C Connector
| Pin | Signal | Type | Description |
|---|---|---|---|
| 1 | GND | Ground | Ground (-) |
| 2 | VBUS | Power (5V-32V) | Redundant power bus (5A total) |
| 3 | 5V_LOGIC | Power (5V) | 5V logic supply (1A total) |
| 4 | 3V3_LOGIC | Power (3.3V) | 3.3V logic supply (2A total) |
| 5 | I2C_SCL | I/O (3.3V, pull-up) | I2C clock signal |
| 6 | I2C_SDA | I/O (3.3V, pull-up) | I2C data signal |
MCU ADC 1 Connector
| Pin | Signal | Type | Description |
|---|---|---|---|
| 1 | GND | Ground | Ground (-) |
| 2 | VBUS | Power (5V-32V) | Redundant power bus (5A total) |
| 3 | 5V_LOGIC | Power (5V) | 5V logic supply (1A total) |
| 4 | 3V3_LOGIC | Power (3.3V) | 3.3V logic supply (2A total) |
| 5 | ADC0 | I/O (3.3V) | Analog input 0 or digital IO 0 |
| 6 | ADC1 | I/O (3.3V) | Analog input 1 or digital IO 1 |
| 7 | ADC2 | I/O (3.3V) | Analog input 2 or digital IO 2 |
| 8 | ADC3 | I/O (3.3V) | Analog input 3 or digital IO 3 |
MCU ADC 2 Connector
| Pin | Signal | Type | Description |
|---|---|---|---|
| 1 | GND | Ground | Ground (-) |
| 2 | VBUS | Power (5V-32V) | Redundant power bus (5A total) |
| 3 | 5V_LOGIC | Power (5V) | 5V logic supply (1A total) |
| 4 | 3V3_LOGIC | Power (3.3V) | 3.3V logic supply (2A total) |
| 5 | ADC4 | I/O (3.3V) | Analog input 4 or digital IO 4 |
| 6 | ADC5 | I/O (3.3V) | Analog input 5 or digital IO 5 |
| 7 | ADC6 | I/O (3.3V) | Analog input 6 or digital IO 6 |
| 8 | ADC7 | I/O (3.3V) | Analog input 7 or digital IO 7 |
MCU IO Connector
| Pin | Signal | Type | Description |
|---|---|---|---|
| 1 | GND | Ground | Ground (-) |
| 2 | VBUS | Power (5V-32V) | Redundant power bus (5A total) |
| 3 | 5V_LOGIC | Power (5V) | 5V logic supply (1A total) |
| 4 | 3V3_LOGIC | Power (3.3V) | 3.3V logic supply (2A total) |
| 5 | IO5 | I/O (3.3V) | Digital IO 5 |
| 6 | IO4 | I/O (3.3V) | Digital IO 4 |
| 7 | IO5 | I/O (3.3V) | Digital IO 3 |
| 8 | IO2 | I/O (3.3V) | Digital IO 2 |
| 9 | IO1 | I/O (3.3V) | Digital IO 1 |
| 10 | IO0 | I/O (3.3V) | Digital IO 0 |
MCU Debug Connector
| Pin | Signal | Type | Description |
|---|---|---|---|
| 1 | GND | Ground | Ground (-) |
| 2 | 3V3_LOGIC | Power (3.3V) | 3.3V logic supply (2A total) |
| 3 | SWCLK | I/O (3.3V) | Microcontroller SWD clock signal |
| 4 | SWDIO | I/O (3.3V) | Microcontroller SWD data signal |
| 5 | RST | Input (3.3V) | Microcontroller reset signal |
| 6 | INTERRUPT | I/O (3.3V) | Microcontroller interrupt signal |
Harnesses
To maintain the high-reliability standards of the LightForce ecosystem, the selection and construction of wiring harnesses are as critical as the autopilot hardware itself. This section details the connector pinouts and recommended wiring standards required to interface with the unit’s power, telemetry, and high-voltage output domains. Given the 25A total system capacity and the use of raw battery voltage on the primary output channels, it is imperative to use correctly gauged high-flexibility silicone wire and locking connectors to mitigate the risks of voltage drop, EMI, and mechanical disconnection during high-vibration operation profiles.
Always turn off the unit before connecting or disconnecting a harness.
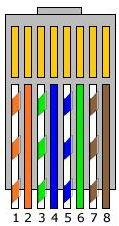
Ethernet
| Pin (Molex Click-Mate) | Pin (RJ45) | Color | Signal | Wire Guage | Description |
|---|---|---|---|---|---|
| 1 | 1 | White-Orange | TR0+ | 24 | |
| 2 | 2 | Orange | TR0- | 24 | |
| 3 | 3 | White-Green | TR1+ | 24 | |
| 4 | 6 | Green | TR1+ | 24 | |
| 5 | 5 | White-Blue | TR2+ | 24 | |
| 6 | 4 | Blue | TR2+ | 24 | |
| 7 | 7 | White-Brown | TR3+ | 24 | |
| 8 | 8 | Brown | TR3+ | 24 |
Sensors
The LightForce OEM integrates a high-fidelity sensing array designed to maintain state estimation in the most demanding flight environments. Navigation is anchored by a triple-band, multi-constellation GNSS receiver capable of centimeter-level RTK precision and dual-antenna heading, providing a robust alternative to traditional magnetometers in high-interference scenarios. Complementing this is the industrial-grade IMU, which utilizes an ultra-low-noise gyroscope and accelerometer architecture. This combination ensures that the autopilot maintains superior vibration rejection and orientation stability, even during high-G maneuvers or in proximity to high-current power distribution systems.
Accelerometer Specifications
| Specification | Value | Unit |
|---|---|---|
| Range | 8 | g |
| Resolution | 16 | bits |
| Sensitivity | 4096 | LSB/g |
| Output Data Rate | 800 | Hz |
| Noise Density | 70 | µg/√Hz |
| Shock Tolerance | 20000 | g |
Gyroscope Specifications
| Specification | Value | Unit |
|---|---|---|
| Range | 500 | º/s |
| Resolution | 16 | bits |
| Sensitivity | 65.5 | LSB/(º/s) |
| Output Data Rate | 800 | Hz |
| Noise Density | 0.0038 | º/s/√Hz |
| Shock Tolerance | 20000 | g |
GNSS Specifications
| Specification | Value | Unit |
|---|---|---|
| Position Accuracy | 1.5 (standalone), 0.01 (RTK) | m |
| Velocity Accuracy | 0.05 | m/s |
| Heading Accuracy | 0.13 (1m baseline) | º |
| Time to First Fix | 1 (hot), 28 (warm), 29 (cold) | s |
| Time to RTK convergence | 10 | s |
| Time to Reacquisition | 1 | s |
| Output Data Rate | 8 | Hz |
| Altitude Limit | <80000 | m |
| Velocity Limit | <515 | m/s |
Flight Termination System (FTS)
The LightForce OEM incorporates a dedicated, independent microcontroller (MCU) to serve as a hardware-level watchdog and Flight Termination System (FTS) controller. This safety architecture ensures that vehicle control can be neutralized or a recovery sequence (such as a parachute deployment) can be initiated even in the event of a total software hang or hardware failure of the primary mission computer.
Isolated Architecture & Power
To ensure maximum reliability, the FTS MCU operates on a simplified, deterministic firmware stack independent of the main Linux-based mission computer.
- Redundant Power: The FTS MCU is powered directly from the primary redundant bus. By utilizing the dual-input (BUSA/BUSB) mux architecture, the FTS remains active as long as either primary power source is viable, eliminating the risk of a single-point power failure disabling the safety system.
- Heartbeat Monitoring: The FTS MCU maintains a continuous bidirectional "heartbeat" with the main mission computer. It monitors critical system health parameters, including CPU responsiveness, sensor loop stability, and software execution states.
Fault Detection & Triggering
If the FTS MCU detects an abnormality—such as a kernel panic, a frozen control loop, or a loss of communication with the mission computer—it can autonomously initiate a termination sequence.
-
GPIO Trigger: The system features a dedicated, high-reliability GPIO output specifically for FTS integration. This signal can be used to trigger external safety hardware, such as:
- Electronic Flight Termination Systems (EFTS).
- Pyrotechnic or spring-loaded parachute deployment systems.
- Independent motor-kill switches.
-
Deterministic Logic: Because the FTS MCU is stripped of complex high-level tasks, its response time to a system-level failure is instantaneous and unaffected by the mission computer's processing load.
FTS Health Telemetry
The status of the FTS MCU and its "handshake" with the mission computer is reported through the telemetry stream. Operators can verify the FTS "Armed" or "Ready" status during pre-flight checks to ensure the safety watchdog is fully synchronized with the flight stack.
Maintenance
To ensure the long-term operation of the LightForce OEM, a few things should be considered. Given the high-vibration environment typical of UAV/UGV/USV/robotics operations, periodic physical and electrical inspections are vital to prevent fatigue-related failures.
- Connection Integrity: Inspect the XT60 and the Molex Micro-Fit connectors for signs of carbon arcing, thermal discoloration, or loose pins.
- Mounting Security: Verify that all mounting standoffs or vibration isolation grommets remain pliable and secure.
- Cleaning: Remove dust or debris from the unit using low-pressure compressed air. In marine or high-humidity environments, inspect for galvanic corrosion on exposed logic pins.
- Version Parity: Ensure the unit is running the latest stable firmware revision. Check the Support Portal quarterly for critical patches and performance optimizations specifically tuned for your hardware revision.
Hardware Changelog
This section outlines the evolution of the LightForce OEM hardware. Users can identify their hardware version by the serial number on the sticker on the PCB.
| Revision | Serial Number Range | Status | Key Changes |
|---|---|---|---|
| v1.0 | TBD | Deprecated | Initial production release |
| v2.0 | TBD | Current | Fixes to known issues in v1.0 and improved GNSS RF path |
| v3.0 | TBD | Planned | Fixes to known issues in v2.0 |
v1.0
Hardware Changes
Not applicable.
Known Issues
- GPIO reference voltage set incorrectly.
- Serial tranceivers are disabled by default.
v2.0
Hardware Changes
- Fixed all known issues with v1.0
- The GNSS active antenna bias circuitry has been redesigned with an improved multi-stage filtering network. This change significantly reduces electromagnetic interference (EMI) on the L1/L2 bands, resulting in:
- Faster RTK integer ambiguity resolution (convergence time).
- Higher Signal-to-Noise Ratio (SNR) in environments with high spectral noise.
- Increased protection against DC bias fluctuations during high-load transients.
- Status LEDs are placed closer to the edge of the PCB to allow for better coupling to enclosure light pipes.
- Boot button is placed closer to the edge of the PCB to improve user experience.
- Add test points for the GNSS debug serial port.
Known Issues
- Voltage drop across the IO board is higher than the desired margins under high CPU/peripheral load scenarios.
Troubleshooting
This section provides diagnostic procedures to identify and resolve common hardware-related issues. The LightForce system is designed with multiple layers of protection; understanding these behaviors is key to distinguishing between a safety feature (like a protective power-cut) and a hardware fault.
Power & Boot Diagnostics
If the unit fails to power on or communicate, follow these diagnostic steps to isolate the cause.
| Symptom | Potential Cause | Action |
|---|---|---|
| Unit fails to boot | Input voltage too low or polarity reversed |
|
| Unit fails to boot (USB-C) | USB-C power delivery |
|
| Unexpected reboots | Power supply voltage too low or cannot supply sufficient current |
|
Output Channel Issues (Channels 1–16)
| Symptom | Potential Cause | Action |
|---|---|---|
| Specific output channel (1–16) has no power | Over-current condition (>5A) tripped the protection IC | Remove the faulty peripheral |
| Servos are jittering, overheating, or failing | Raw battery voltage (VBUS) exceeds actuator rating | Ensure battery voltage (2S–7S) matches peripheral voltage specifications |
| Total system power cuts out under heavy load | Aggregate current draw exceeded the 25A limit | Reduce simultaneous actuator loads to stay within the 25A system ceiling |
GNSS Troubleshooting
| Symptom | Potential Cause | Action |
|---|---|---|
| Unable to achieve an RTK Fixed solution | Low-quality antenna or poor sky visibility |
|
| Inaccurate GPS heading | Insufficient separation between GNSS antennas | Increase physical separation between GNSS antennas |